Top RIA Standards for Industrial Robot Buyers

Industrial robot purchases involve more than payload, reach, and cycle time. Buyers must also examine the safety standards shaping the robot cell, its controls, and its integration. In the United States, ANSI/RIA R15.06 is a central reference for industrial robot safety. Related standards may address risk assessment, safeguarding, and system integration. Requirements and editions can vary by market, so confirm which apply to your installation.

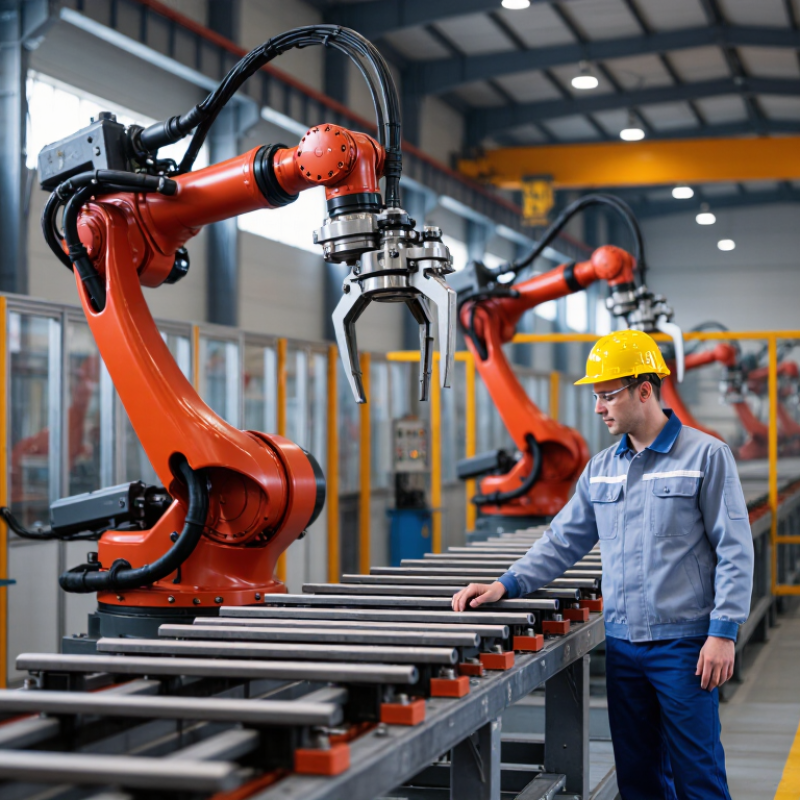
Start with the real work area. Picture an operator reaching toward a fixture while a robot arm moves nearby. Ask how access is controlled, how the system responds to faults, and who verifies the safeguards. Robot-safety specialist Roberta Nelson Shea’s guidance underscores a practical principle: risk assessment should inform design, not become paperwork added at the end. That distinction matters. A compliant component alone does not guarantee a safe cell; the complete application needs review by qualified professionals.

This guide outlines key RIA standards buyers should understand before choosing equipment or approving an integrator’s proposal. It also highlights useful questions about documentation, training, and commissioning. Standards are essential, but they cannot replace careful judgment on the factory floor. That part is easy to underestimate.
Top RIA Standards for Industrial Robot Buyers

Understanding the Role of RIA Standards in Industrial Robotics

Top RIA Standards for Industrial Robot Buyers

RIA standards help buyers evaluate safety beyond a robot’s speed, payload, or reach. ANSI/RIA R15.06 and the ISO 10218 framework address industrial robot and system safety, including risk assessment, protective measures, and safeguarding. In practice, that means checking the complete work cell: the robot, gripper, tooling, fixtures, access doors, and how people enter the area. A safety fence around the arm may not protect someone reaching toward a sharp part or an unexpected pinch point. Details matter.

The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023, with about 4.28 million operating units. At that scale, consistent safety guidance helps buyers compare integration plans and ask precise questions about hazards, stopping distances, and maintenance access. RIA technical guidance can support those discussions, but a standard cannot assess a factory’s exact workflow for you. That gap matters. A site-specific risk assessment is still essential, especially when operators share space with equipment or change tasks between shifts. Buyers should request documented safety assumptions and verify that safeguards work under real operating conditions—not just during a demonstration. That is easy to overlook.

Identifying the Standards That Apply to a Robot System

Top RIA Standards for Industrial Robot Buyers
Identifying the Standards That Apply to a Robot System

A robot purchase rarely involves the arm alone. Standards apply to the complete application: robot, gripper, fixtures, controls, guarding, and surrounding work area. In the United States, ANSI/RIA R15.06 addresses industrial robot safety, including robot and system integration requirements. Collaborative applications may also call for review of ISO/TS 15066, depending on the task and operating conditions. The right scope depends on access, speed, hazards, and how people interact with the cell.

Tips: Draw the cell boundary before comparing proposals. List every tool, conveyor, access door, and operating mode. Ask who performs the risk assessment and provides validation records. Confirm current editions and local requirements with a qualified safety professional.

A standard number alone does not prove a cell is safe. Request a documented risk assessment, safety-function details, and test evidence for the finished installation. Electrical and machinery requirements may also apply, depending on the site and process. A manual loading point needs different safeguards from an unattended cell. That distinction is easy to miss. Revisit the assessment when tooling or production steps change; a checklist cannot replace observing the actual workflow.

Assessing Robot, Workcell, and Operator Safety Requirements

Top RIA Standards for Industrial Robot Buyers

A robot’s safety rating does not make the whole installation safe. Buyers should assess the robot, end effector, workpiece, tooling, and operator tasks as one system. ANSI/RIA R15.06 and ISO 10218 provide key requirements for industrial robot and workcell safety. A documented risk assessment should identify hazards during production, teaching, cleaning, troubleshooting, and maintenance.

NIOSH reviewed OSHA investigations of robotics-related incidents from 1992 to 2017 and documented 41 worker deaths. The finding is a reminder that danger often appears during intervention, not normal automated cycles. Check reach and stopping distance at the cell boundary. Verify gate interlocks, presence sensing, emergency stops, and safe restart behavior under realistic conditions. A test with an empty gripper may miss the longer stopping distance caused by a heavy load.

Small gaps matter. Operators need clear procedures, practical training, and enough space to work without reaching through safeguards. Maintenance access should not depend on someone improvising around a jammed part. Ask integrators to show validation records and explain how protective measures perform after changes. Even a compliant cell can feel awkward to use; that discomfort deserves investigation, not dismissal. Safety depends on daily work as well as design.

Top RIA Standards for Industrial Robot Buyers — Assessing Robot, Workcell, and Operator Safety Requirements

Publication years of key industrial robot safety standards and guidance documents

ISO 10218-1 addresses industrial robot safety, while ISO 10218-2 covers robot applications and cells. ISO/TS 15066 provides guidance for collaborative robot applications. The years shown are publication years, not safety scores; check applicable national adoptions and current requirements when planning a project.

Checking Integration, Installation, and Operating Conditions

Before buying a robot, map the entire cell, not just the arm’s reach. Include the gripper, cables, fixtures, and workpiece in the swept-volume check. A tool that clears a drawing may still strike a guard during a real cycle. Small details matter. Check how the robot communicates with conveyors, sensors, and the safety system. Define who owns each interface; gaps often appear between supplier and integrator. Use current applicable RIA/ANSI and ISO robot-safety standards as a baseline, and confirm which editions and requirements fit the application.

Installation conditions can change performance and safety. Measure floor flatness and load capacity, then check for vibration near presses or heavy machinery. Leave room to access connectors, service panels, and emergency stops without reaching through a hazard zone. Verify guard height, interlock placement, and stopping distance after the equipment is installed. Looks clear on paper. A neat layout can still hide a poor maintenance route, so walk the cell with operators before fixing the design.

Operating limits deserve equal attention. Compare the site’s temperature, humidity, dust, and washdown exposure with the robot’s documented limits. Confirm payload includes the tool and cables, not only the part. Test representative cycles at realistic speeds, including jams and recovery steps. Record results and train operators on the actual cell. Not always. Assumptions about “normal” production can miss awkward parts, rushed changeovers, or a cable that snags after weeks of use.

Verifying Compliance Through Risk Assessment and Validation

Compliance is not established by a certificate alone. Buyers should connect applicable RIA requirements to the robot’s task, tooling, and cell layout. A risk assessment should cover automatic operation, teaching, maintenance, and fault recovery. Consider reach, pinch points, payload movement, sharp workpieces, and unexpected restart. Small details matter. A gate beside a moving conveyor may create a different exposure than one at a fixed workstation. Record each hazard, its severity and likelihood, and the safeguards selected. Assign an owner and a practical method for checking each safeguard.

Validation tests whether those safeguards work as intended under real operating conditions. Check guard interlocks, emergency stops, safe speed limits, and restart behavior. Test foreseeable situations, including a dropped part or a worker entering during setup. Document test conditions, results, and any corrective action; photos and measured stopping distances can make records more useful. A neat risk register can still hide a weak assumption, especially when production changes after approval. Reassess the cell when tooling, software, payloads, or work patterns change. Keep acceptance criteria clear before testing, so a passed check means more than “it seemed fine.”

Top RIA Standards for Industrial Robot Buyers — Verifying Compliance Through Risk Assessment and Validation
Standard or Regulation Primary Scope What Buyers Should Verify Risk Assessment and Validation Evidence
ANSI/RIA R15.06-2012 U.S. industrial robot and robot-system safety requirements. This edition adopts the 2011 editions of ISO 10218-1 and ISO 10218-2. Confirm which edition applies to the project and review the robot, end effector, safeguarding, operating modes, and integration responsibilities as parts of the complete application. Request the system risk assessment, safety-function documentation, safeguarding layout, and test records. Verify protective measures on the installed cell, not only on the robot as supplied.
ISO 10218-1:2025 and ISO 10218-2:2025 International requirements for industrial robot manufacturers (Part 1) and robot applications and cells (Part 2). Check the edition specified by the contract and the applicable national adoption. Establish which party is responsible for the robot, application, and system-level integration. Obtain documentation showing the applicable edition, identified hazards, protective measures, and validation results. Confirm that the final installation and intended tasks are covered.
ISO 12100:2010 General principles for machinery risk assessment and risk reduction across the machine life cycle. Check that the assessment covers intended use, reasonably foreseeable misuse, setup, operation, maintenance, and foreseeable interactions with people. Review the hazard identification, risk estimates, selected risk-reduction measures, and residual-risk information. Reassess when the process, tooling, layout, or operating conditions change.
ISO 13849-1:2023 Design of safety-related parts of control systems, including determination of required and achieved performance levels. Ask for the required Performance Level (PLr) for each safety function and the design evidence supporting the achieved Performance Level (PL). Review safety-function specifications, architecture, component data, calculations, and validation records. Test functions such as protective-stop and guard-interlock responses under defined conditions.
IEC 62061:2021, including applicable amendments Functional safety of safety-related control systems for machinery, using a Safety Integrity Level (SIL) methodology. Confirm whether this standard or ISO 13849-1 is used for the relevant safety functions, and require a consistent, documented approach for each function. Review the safety requirements specification, SIL determination, design and verification records, and validation results. Do not treat a component rating alone as proof of system-level compliance.
ISO/TS 15066:2016 Guidance for collaborative industrial robot systems, supplementing the industrial robot safety framework. Determine the specific collaborative operating mode and assess the complete application, including the robot, tool, workpiece, speed, path, and potential contact hazards. Request application-specific risk assessment and evidence for the chosen safeguards. Where power-and-force-limiting is used, verify that relevant contact conditions are assessed and validated; collaborative capability alone does not make an application safe.
OSHA 29 CFR 1910.212 U.S. general requirements for machine guarding against hazards such as points of operation, ingoing nip points, and rotating parts. Check that guarding addresses hazards throughout the robot cell, including peripheral equipment, transfer points, and access during foreseeable tasks. Inspect guard coverage, openings, access points, and the relationship between guarding and hazardous motion. Document corrective actions for any exposed hazards.
OSHA 29 CFR 1910.147 U.S. control of hazardous energy during servicing and maintenance, including applicable lockout/tagout requirements. Verify that energy sources are identified and that the employer’s energy-control procedures address the installed robot cell and its ancillary equipment. Review energy-control procedures and training records; verify isolation and the means to prevent unexpected startup during maintenance. Account for electrical, pneumatic, hydraulic, and stored energy where present.
NFPA 79:2024 Electrical requirements for industrial machinery in the United States. Check the project’s applicable edition and review machine electrical design, disconnecting means, control circuits, wiring, and documentation. Request electrical drawings and inspection or test records. Verify that the installed machine matches the documentation and that electrical safety checks are completed before operation.
Buyer note: Applicable editions and legal requirements depend on jurisdiction, contract, installation date, and project scope. Standards compliance should be verified for the complete integrated application through documented risk assessment, inspection, and validation; a robot’s product documentation alone does not establish that the finished cell is safe.